CNGBS automation units are four building blocks of a flexible production cell: the ARM300S autonomous mobile robot, the T2-K5 machine tending robot, the GBS-i3 vacuum suction handling machine and the GBS-MD palletizing lift base. One supplier, one control philosophy, rapid deployment.
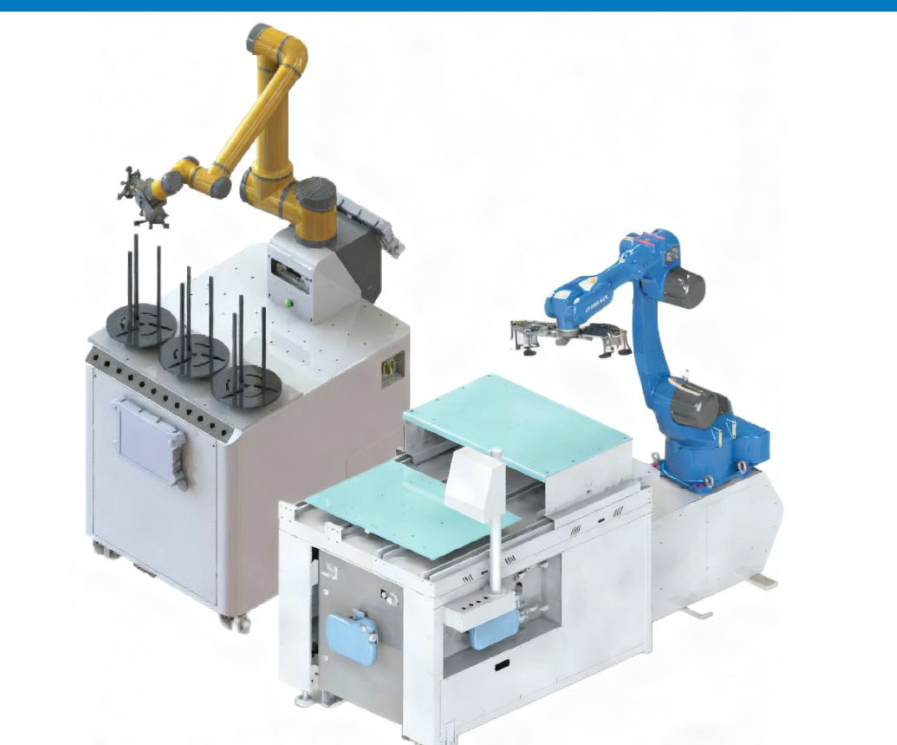
Four units that cover moving, tending, gripping and lifting — combine them into one flexible cell or deploy each on its own.

Self-navigating composite robot for part fetching, transfer, assembly and machine loading across moving work areas.
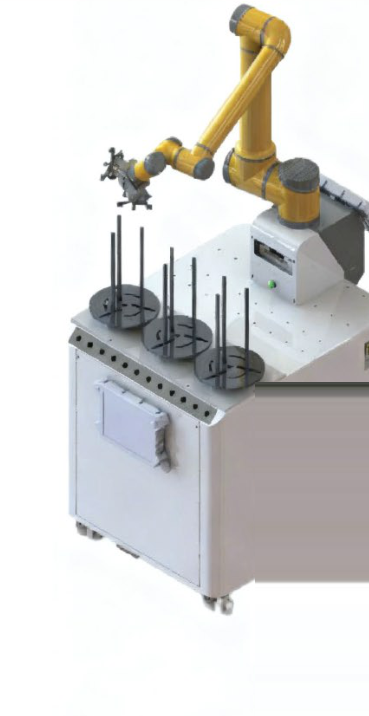
Ultra-compact tending unit for CNC lathes, machining centers and grinders — deployed in hours, no layout changes.
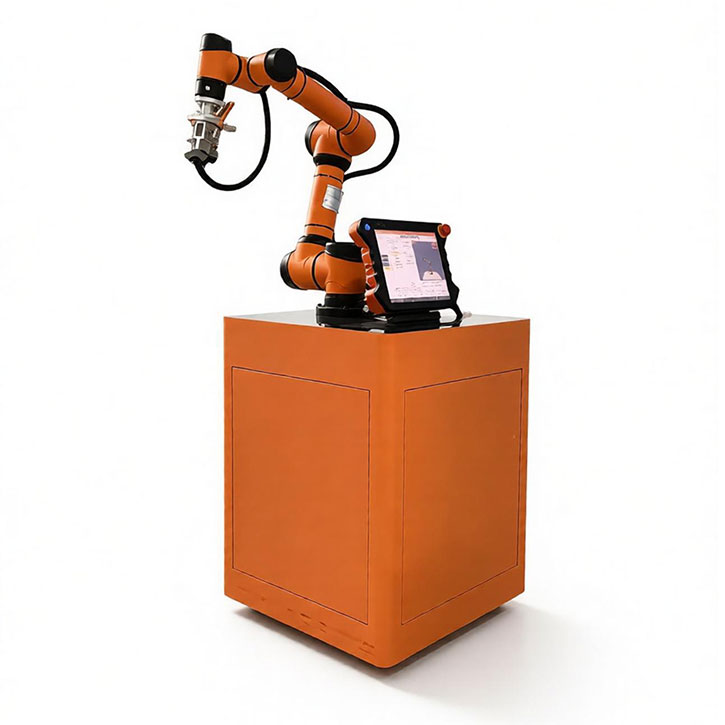
Vision-guided picking of sheets, cartons, soft packages and thin sheet metal — no precision tooling required.

Raises palletizing height beyond 2 m without upsizing the robot — base height follows the pallet layers automatically.
The ARM300S combines an autonomous mobile base (AMR), a collaborative arm, a vision system and a gripper in one body. The self-developed ARCS embodied control system drives the base and the arm from a single controller — no second control cabinet — for part fetching, assembly, transfer and machine loading across moving work areas.
| Item | ARM300S (AMR base, excl. arm) |
|---|---|
| Dimensions (L×W×H) | 1000×700×600 mm, tolerance ±2 mm |
| Load surface (L×W) | 650×620 mm |
| Self weight | 250 kg (excl. arm) |
| Max payload | 300 kg (incl. arm and carrier) |
| Drive | Dual-wheel differential · 2 laser sensors |
| Max speed | 1.3 m/s |
| Working speed | 1.0 m/s forward / reverse (configurable) |
| Turning radius | 0 mm (rotation radius 550 mm) |
| Gradeability | 6° · obstacle 10 mm · gap 30 mm · clearance 25 mm |
| Aisle width | Travel ≥900 mm · turning ≥1300 mm |
| Station positioning | ±10 mm · floor flatness ≤6 mm |
| Battery | 48 V 52 Ah lithium |
| Endurance | 6 h (300 kg full load) |
| Charging | Manual (standard) / automatic pile (optional), max 15 A · ~3 h from 15% to 95% |
| Protection | IP54 · EN ISO 13849-1 PL=d, CAT 3 |
Typical applications: part fetching and assembly, machine loading, warehouse sorting, semiconductor transfer and inspection — fast to deploy and flexibly expandable. Optional items: column, automatic charging pile, self-developed vision camera.
A tending unit designed for a single machine tool: ultra-compact footprint from just 0.4 ㎡; fast retraction keeps the manual operating position free; outstanding value; and no changes to the existing shop-floor layout. Supports CNC lathes, machining centers and grinders.
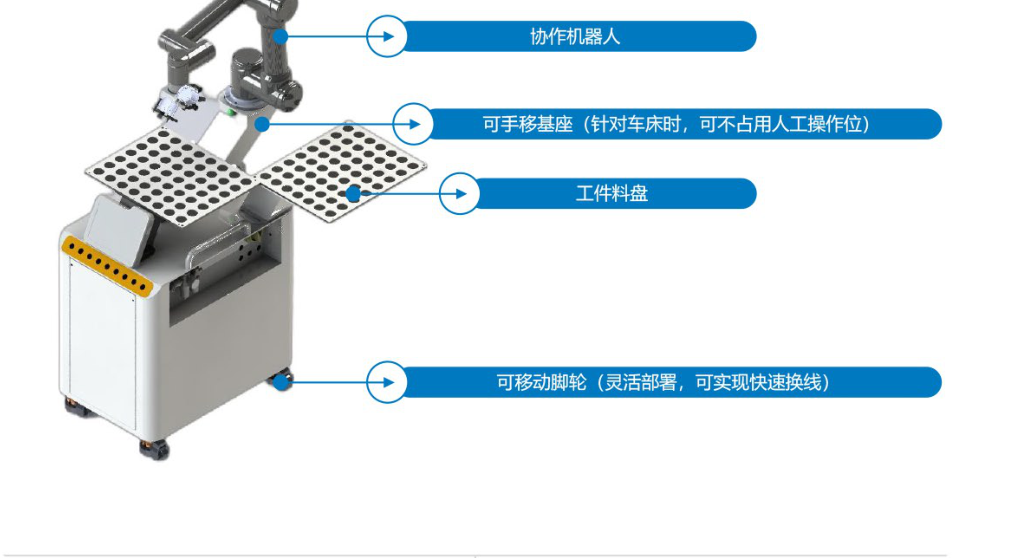
| Item | T2-K5 (WEOD Version) |
|---|---|
| Robot | Articulated collaborative robot |
| Robot payload (incl. end effector) | 5 kg |
| Degrees of freedom | 6 axes |
| Working radius | 886.5 mm |
| Robot repeatability | ±0.05 mm |
| Max. workpiece weight | 1.5 kg |
| Feeding method | Tray |
| Tray size | 500×400 mm |
| Number of trays | Two as standard |
| Capacity per tray | Approx. 56 pcs (φ40 parts) |
| Footprint500×750 mm retracted, single tray | Single tray 500×930 mm / double tray 850×1055 mm |
| Supported machines | CNC lathes / machining centers / grinders, etc. |
From the programming interface to on-site deployment, the WEOD tending robot is designed so that anyone can run automation.
Typical solution: CNC machine tool (lathe, VMC, grinder, etc.) + T2-K5 tending robot for automatic loading and unloading of small parts on a single machine.
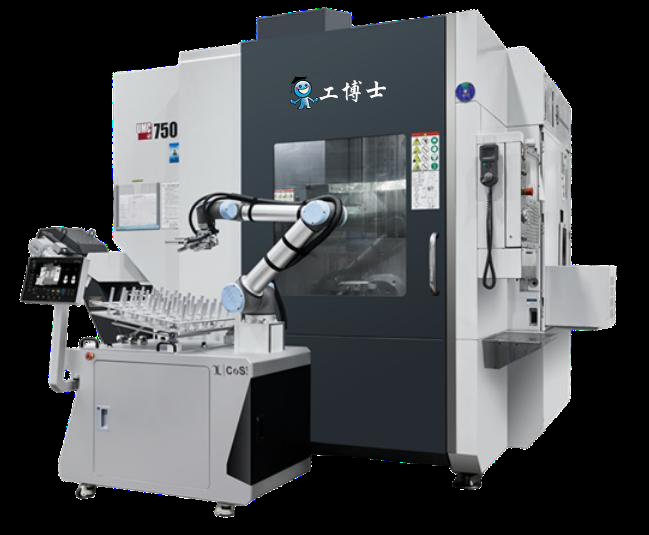
| Item | Spec | Qty | Unit | Remarks |
|---|---|---|---|---|
| Machine tending unit | K5-WEOD | 1 | set | WEOD version, complete unit |
| Workpiece tray | Custom | 2 | pcs | |
| Machine modification | 1 | unit | Automatic door modification I/O signal interfacing | |
| Installation & commissioning | 1 | time | Within the Pearl River Delta | |
| Freight | 1 | time |


Built around a 6-axis collaborative robot with the control cabinet and teach pendant integrated into one compact floor cabinet, the GBS-i3 ends in a custom vacuum suction array. It grips sheets, cartons, soft packages and thin sheet-metal parts without precision tooling — for picking, loading, palletizing and depalletizing of flat workpieces.
| Item | GBS-i3 |
|---|---|
| Degrees of freedom | 6 axes · joint range ±360° (J1–J6) |
| Payload | 3 kg · self weight 16 kg |
| Working radius | 625 mm |
| Repeatability | ±0.02 mm |
| Tool speed | ≤1.9 m/s · joint speed J1–J3 178°/s, J4–J6 237°/s |
| Power | Average 150 W / peak 1000 W |
| Protection | IP54, cleanroom Class 5 · any-angle mounting |
| Control cabinet (CB-M) | 380×350×265 mm · 15 kg · 100–240 VAC 50/60 Hz |
| I/O | 16 DI / 16 DO · 4 AI / 4 AO · safety I/O 16 / 16 |
| Communication | Ethernet, Modbus-RTU/TCP (Profinet optional) |
| Teach pendant (TP) | 355×235×54 mm · 1.57 kg · IP43 · drag teaching / graphical programming |
| Openness | SDK C/C++/C#/Lua/Python · ROS |
| Suction System | Typical Configuration |
|---|---|
| Vacuum actuating unit | Vacuum generator + solenoid valve group + vacuum pressure switch |
| Suction fixture | Custom suction array on quick-change aluminium bracket |
| Grip confirmation | Vacuum pressure switch feedback |
| Air preparation | Filter-regulator unit (FRL) |
Certification: EN ISO 13849-1:2015 (PL=d, CAT 3) functional safety · ISO/TS 15066 · CE, NRTL, KCs, CR · cleanroom Class 5. Core components are domestically sourced.
A servo-driven lifting column mounted under the palletizing robot — effectively the robot's seventh axis. The base height follows the pallet layers automatically, keeping the arm at its optimal working height and extending palletizing height beyond 2 m without upsizing the robot, while lowering the robot selection cost. Steel column, servo drive, guides, electrical cabinet and HMI are integrated; it plugs into mainstream industrial robots and cobots via the standard flange.
| Item | GBS-MD |
|---|---|
| Structure | Column-type lifting base — square steel guide posts + precision sliders |
| Lifting stroke | 500 mm |
| Drive | Servo motor + precision gearbox (lead screw / chain / rack-and-pinion by stroke) |
| Rated thrust | 4,000–8,000 N (by load class) |
| Load capacity | ≤500 kg (robot + end load) |
| Lifting speed | 20–100 mm/s, load-independent, settable |
| Repeatability | ±0.5–1.5 mm |
| Control | HMI touch screen — height presets, per-layer auto follow, manual jog |
| Power supply | 220 V AC / 380 V AC, 50 Hz |
| Limit protection | Origin / upper / lower limit switches + electronic soft limits |
| Protection | IP54 electrics · optional dust bellows · 5–45 ℃ |
| Robot interface | Standard robot mounting flange, mainstream brands; TCP/IP or I/O handshake |
Selection notes: verify the overturning moment from robot weight + end load + center-of-gravity offset; I/O handshake or TCP/IP keeps lift and palletizing cycles in sync; add the dust bellows and raise the protection class for outdoor or dusty environments. The servo brake self-locks on power loss to prevent sinking.